Data Scientist · Lyft
Leading optimization and machine learning systems for real-time driver incentives, earnings prediction, and guarantee forecasting.
I build optimization, machine learning, and real-time AI systems.
Currently a Data Scientist at Lyft.
Previously a Senior Associate Data Scientist at NTT DATA.
Building intelligent systems from research through production.
Leading optimization and machine learning systems for real-time driver incentives, earnings prediction, and guarantee forecasting.
Built edge AI, multi-agent RAG, computer vision, and full-stack 3D object detection systems for production use cases.
Researched real-time UAV obstacle avoidance, small-object detection, and path planning on an 11TB+ imagery dataset.
Deployed Pangeo on AWS and Kubernetes, orchestrating and scaling 128 Docker containers.
Improved a Jetty-based signup service and its test coverage, cutting request time by up to 30%.
High-impact systems across optimization, generative AI, and computer vision.
A multi-agent stock research pipeline combining technical, news, quantitative, and risk agents with a human approval checkpoint.
Led a cross-functional 0-to-1 launch of low-latency incentive optimization services driving $30M+ in annual profit.
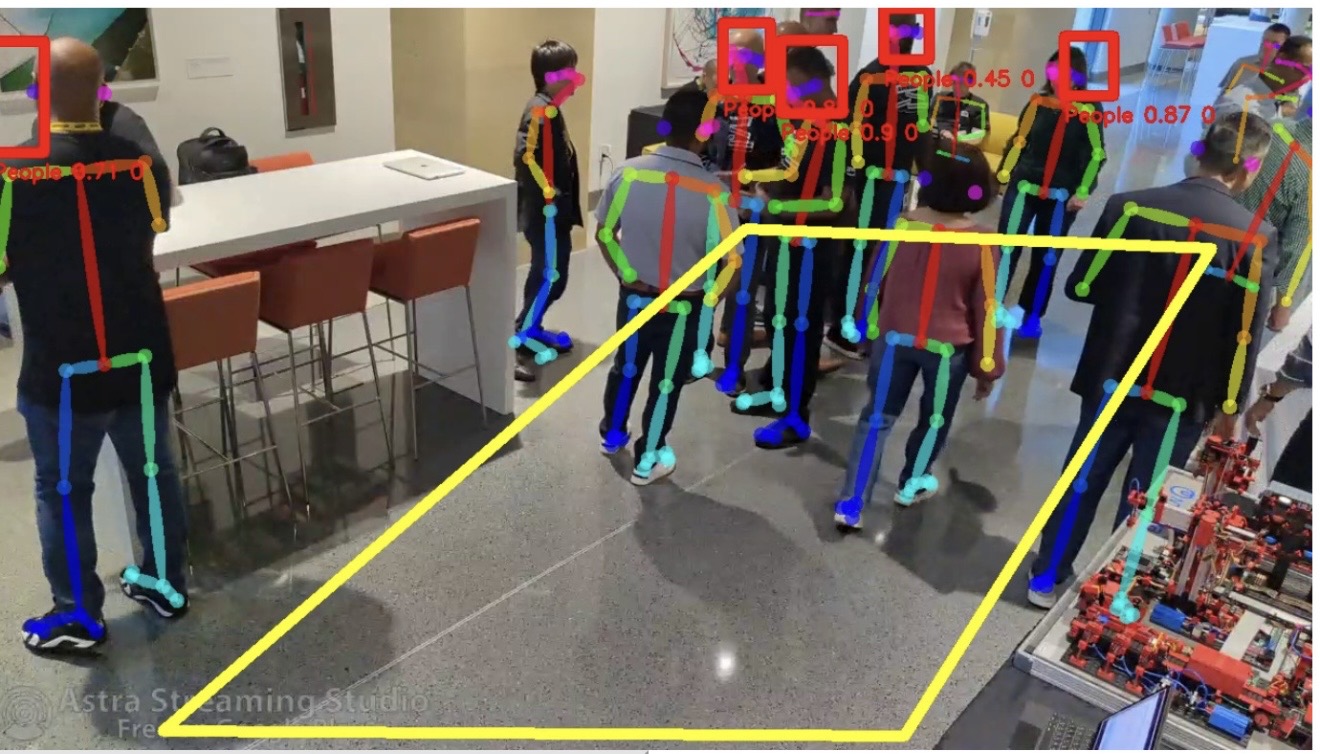
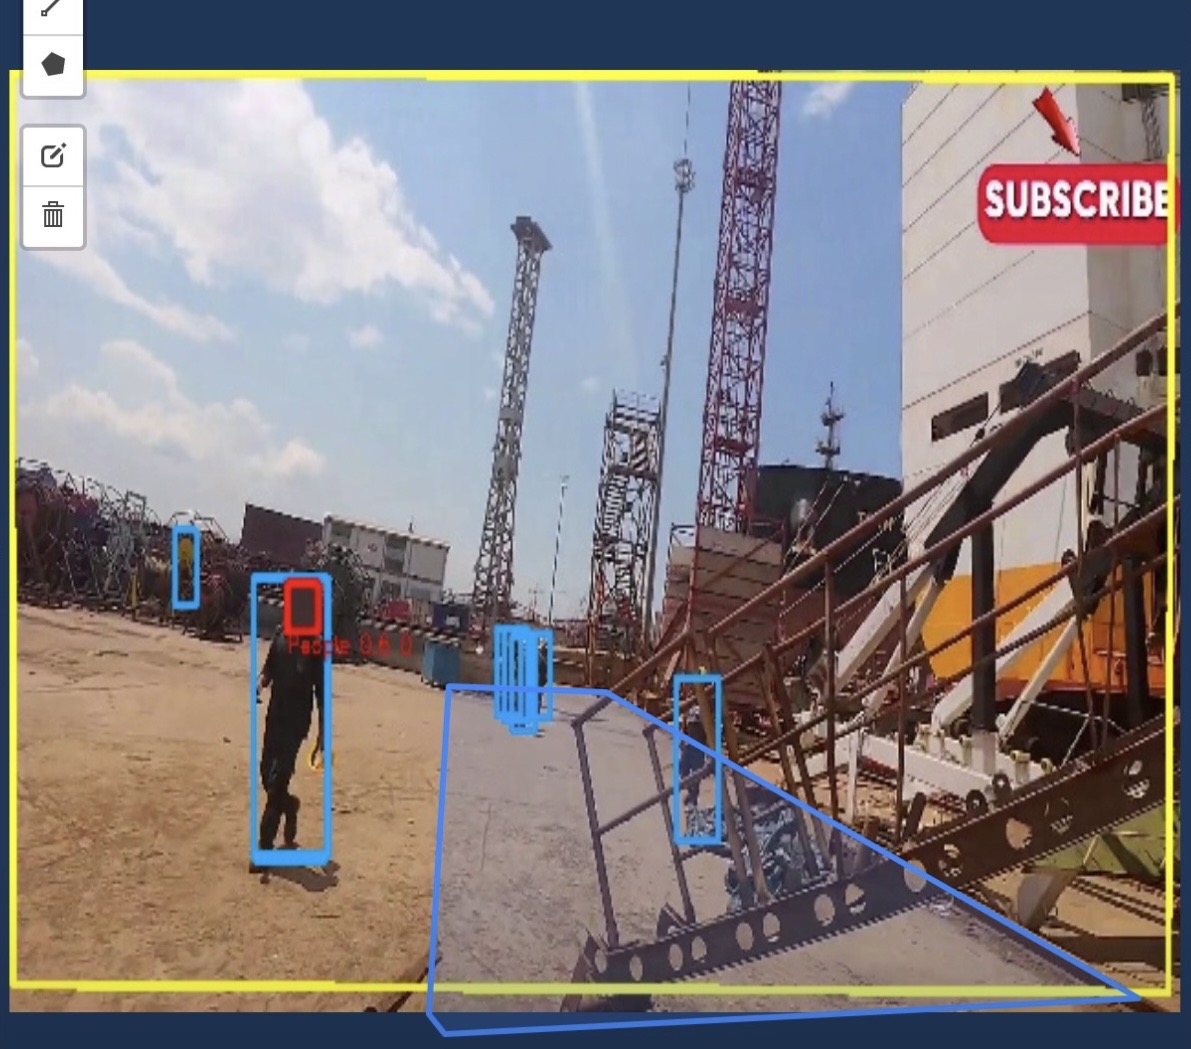
Designed custom inference algorithms and modular streaming APIs for a patent-filed real-time detection system.
Detected people and safety helmets with YOLO, estimated each person's position from a monocular camera using geometric algorithms, and applied polygonal safety zones to highlight workers inside restricted areas without helmets using red bounding boxes.
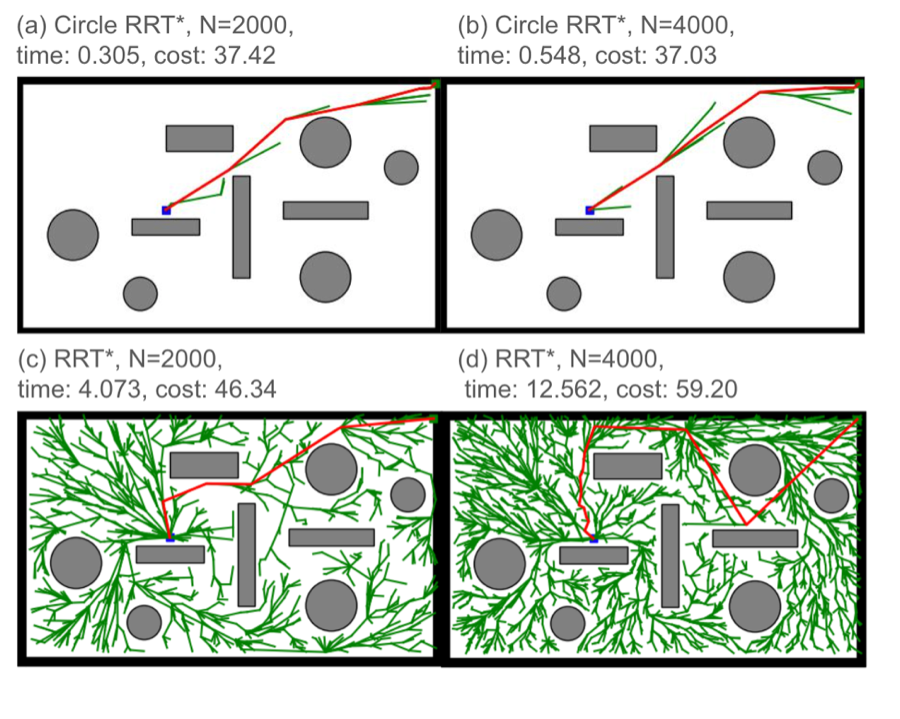
Combined object detection with classic pathfinding to reduce computation time by 20% and path length by up to 6%.
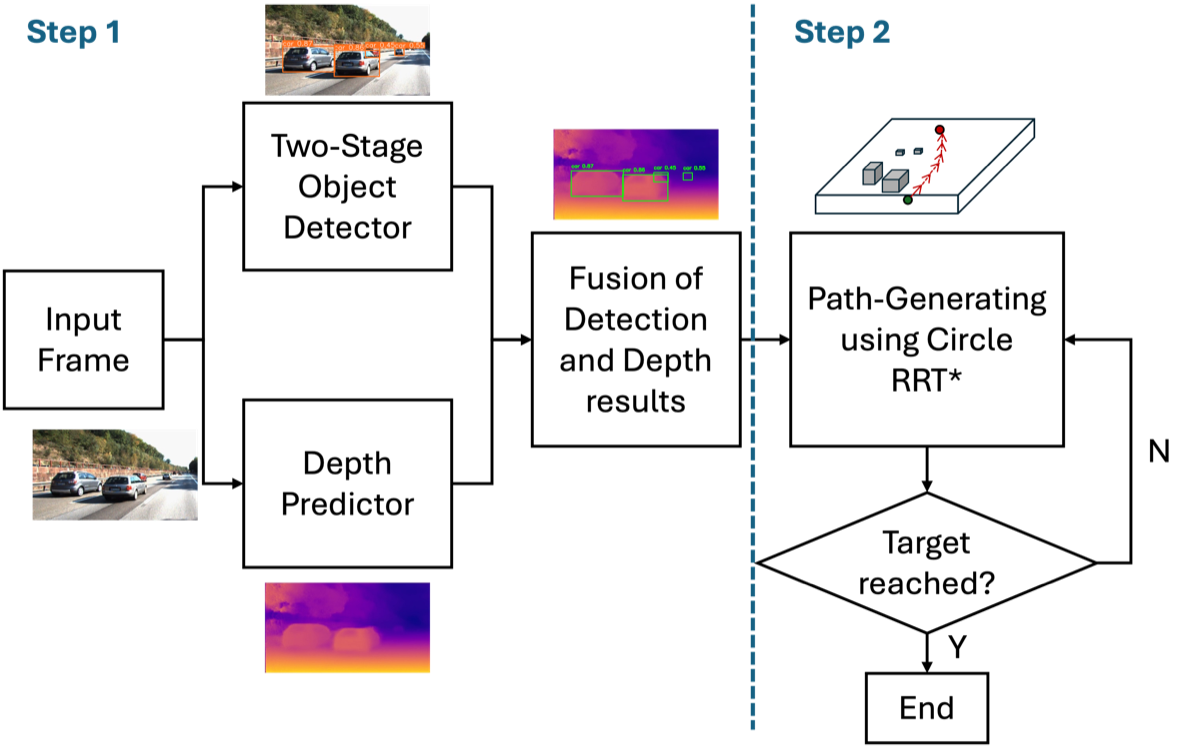
Research in UAV perception, path planning, responsible innovation, and computer vision systems.
Interactive notes I build while learning ML systems.
An interactive pipeline map of 40+ LLM speed and memory techniques, plus a VRAM and decode-speed lab for an 8B model.
An interactive walkthrough of a LangGraph run and the architecture around a production agent harness.
Tools I use to build, validate, and ship.
LLM fine-tuning (LoRA), quantization, LangChain, LangGraph, RAG, PyTorch, TensorFlow, CatBoost, computer vision
Python, TypeScript, JavaScript, Java, C/C++, SQL, NoSQL, Shell
FastAPI, Flask, Django, Express.js, Docker, Kubernetes, AWS, Azure, Terraform, CI/CD, Spark
React, React Native, Next.js, Tailwind CSS
A foundation in software engineering and intelligent systems.
GPA 4.0/4.0 with a full scholarship.
Interactive notes I build while learning ML systems.
An interactive pipeline map of 40+ LLM speed and memory techniques, plus a VRAM and decode-speed lab for an 8B model.
An interactive walkthrough of a LangGraph run and the architecture around a production agent harness.